ROBOTICS / TEAM 1885 / 2026 REBUILT
Rocky FRC.
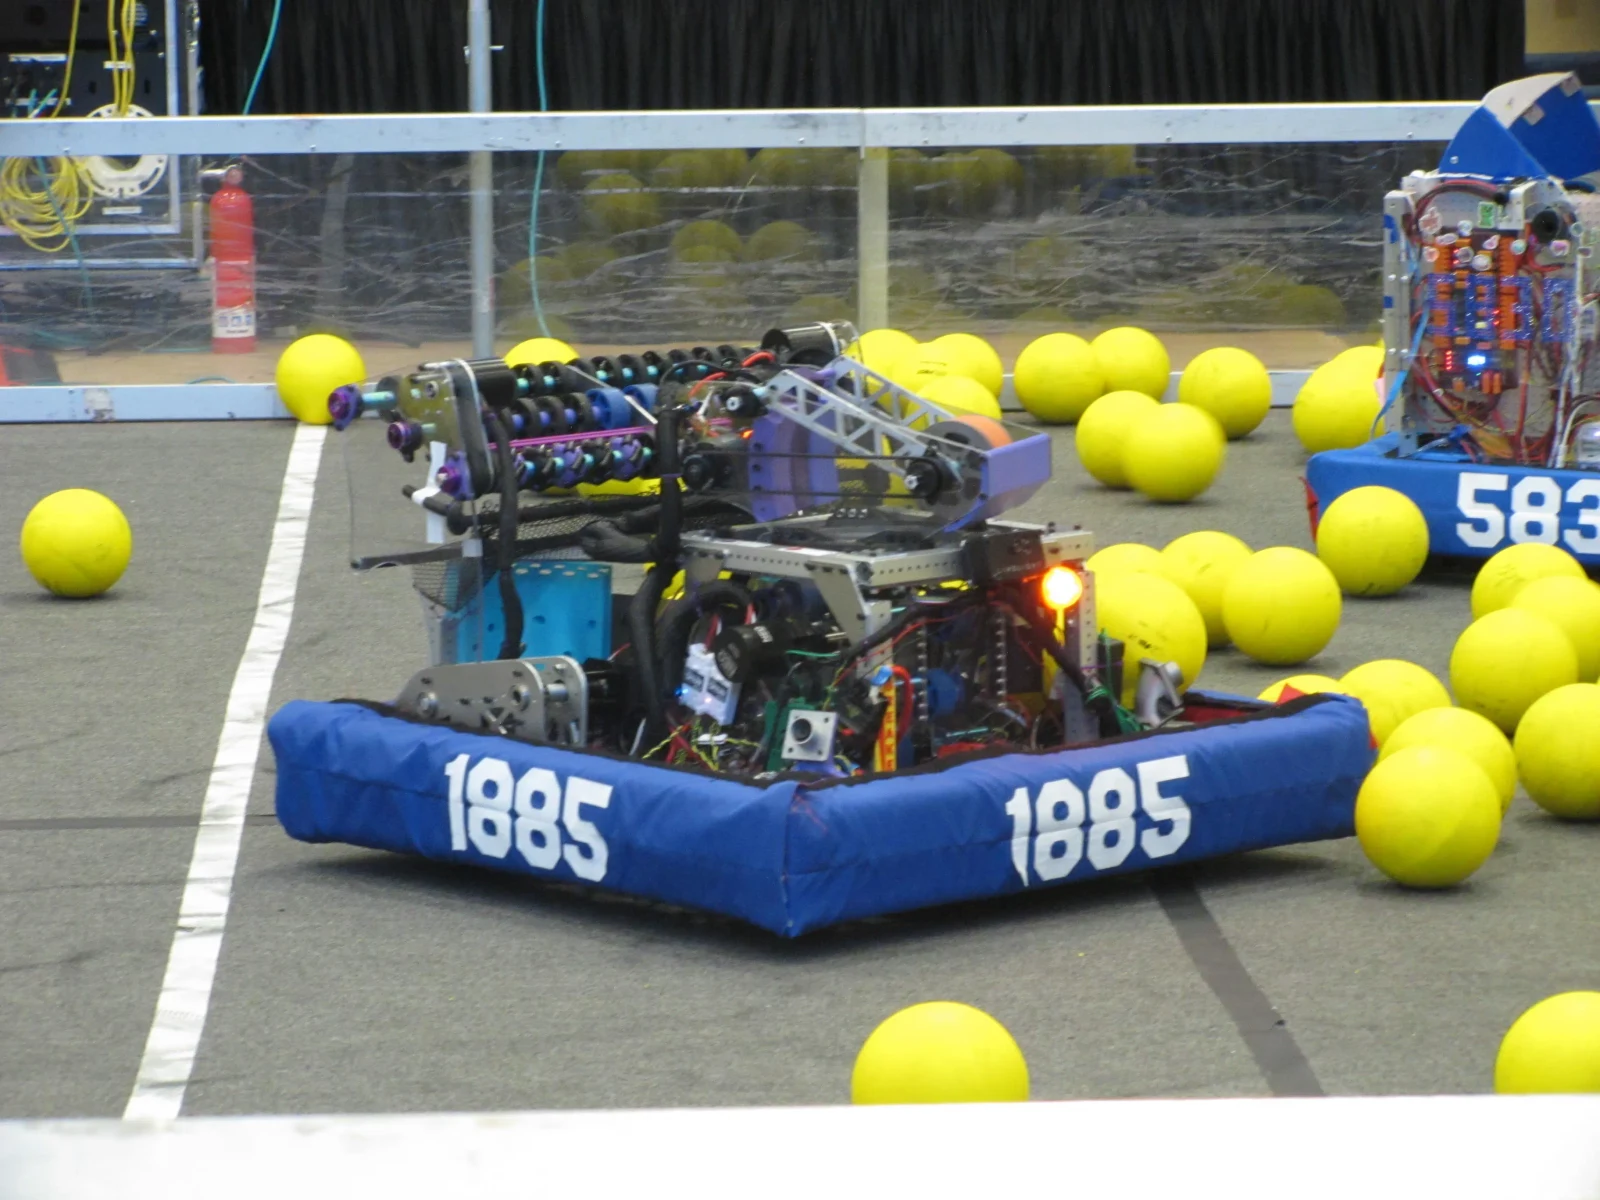
Aim while moving. Rocky’s Java control system brings together swerve drive, vision localization, and a motion-compensated turret for Comet Robotics’ 2026 robot.
Keep moving.
Stay on target.
Rocky’s software coordinates driving, aiming, and firing through a command-based Java architecture. Its shot calculator uses robot position, velocity, and estimated ball flight time to compensate for motion, then selects turret angle, flywheel speed, and hood angle for hub scoring or feeding.
- Motion-compensated aiming. An iterative lookahead refines the shot distance and direction while accounting for movement. Interpolated lookup tables supply flywheel speed, hood angle, and flight time.
- Vision and odometry. PhotonVision cameras and a Limelight feed position estimates into the drivetrain, with observation filtering to reject unreliable measurements.
- Autonomous routines. PathPlanner paths combine driving with named intake and shooting commands.
- Coordinated firing. Automatic firing checks shot validity, turret alignment, and flywheel speed before engaging the kicker.
- Logging and simulation. AdvantageKit records subsystem and aiming data, with separate hardware and simulation implementations for development.
Built with: Java, WPILib, PathPlanner, PhotonVision, and AdvantageKit.
The hardware
behind the software.
- MK5N swerve modules with R2 gearing.
- Kraken X60 drive motors and Falcon 500 steering motors.
- Two ArduCam cameras with an Orange Pi 5, plus a Limelight 3G.
- Turret, flywheel, adjustable hood, intake, indexer, and kicker subsystems.
Technical details from the team’s C2026-REBUILT repository ↗.